|
Walker Byrnes I am a PhD student in the PAIR Lab at Georgia Tech and a Research Engineer at the Georgia Tech Research Institute in Atlanta. I am interested in generalizable autonomy and AI for robotics: building intelligent systems that are intuitive, flexible, and ubiquitous. My current focus areas include reinforcement learning, learned general reward/value models, and continual learning systems. With my academic research I aim to equip robots with the tools needed to perform challenging manipulation tasks, understand and learn from mistakes, and self-improve throughout their lifespan. In my professional capacity, I lead the Machine Learning and Data Analytics branch in the Intelligent Sustainable Technology Division. I am also the current R. Harold and Patsy Harrison Faculty Fellow in Poultry Processing. My team and I conduct applied research in robot learning and AI perception with a focus towards food production and agriculture. We work in unstructured environments where traditional robots are not effective due to insufficient dexterity and intelligence. The heterogeneous and complex physical properties of food products and the variance of small batch manufacturing poses significant barriers to the reliable use of robots, necessitating the use of frontier models and new techiques. |
|
Research |
|
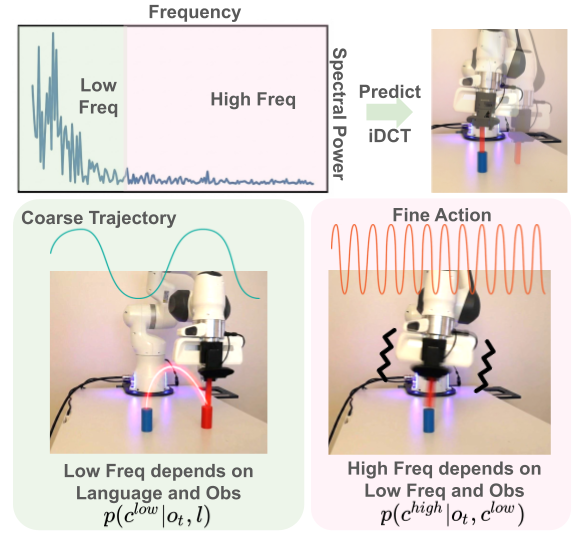
Hierarchical Policy Learning via Spectral Decomposition
Shuxin Cao, Liquan Wang, Walker Byrnes, Yiye Chen, Yilun Du, Animesh Garg International Conference on Machine Learning 2026 project page / arXiv We develop Causal Spectral Policy (CSP), a hierarchical frequency domain behavior cloning architecture for robot manipulators. Low-frequency components capture global motion trajectories, while high-frequency components encode precise timing, alignment, and contact behaviors. |
|
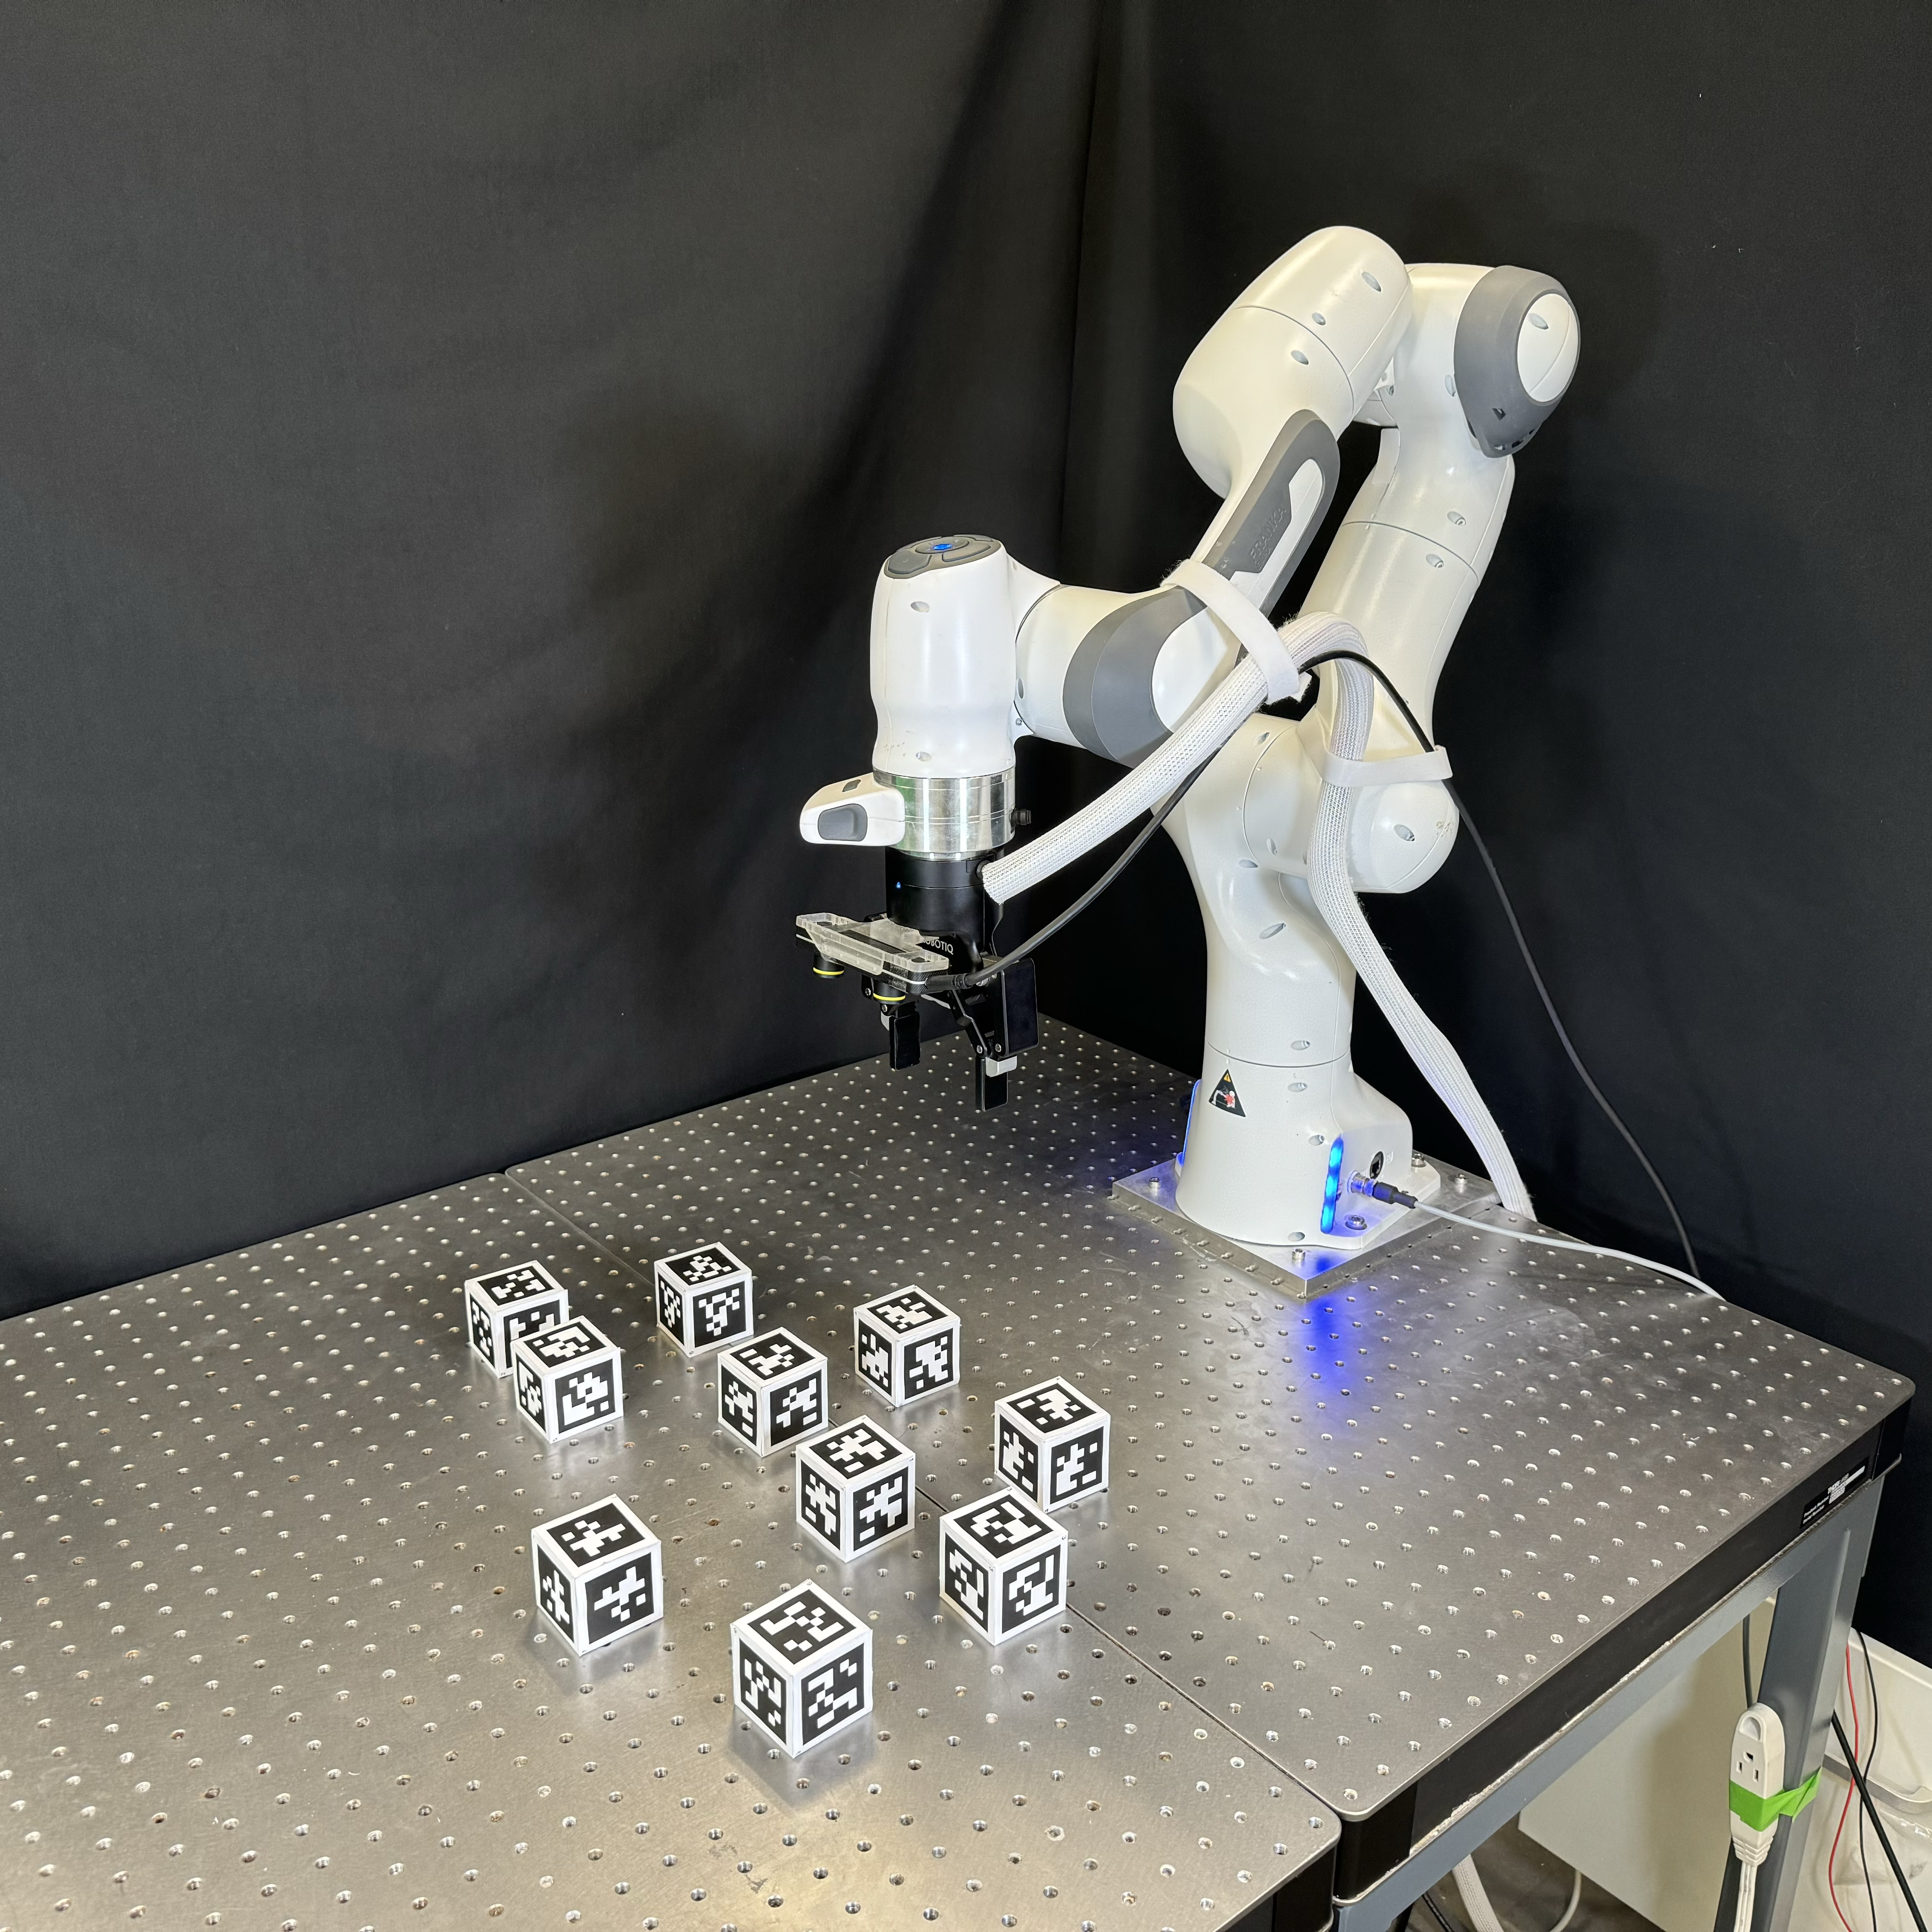
CLIMB: Language-guided Continual Learning for Robot Task Planning
Walker Byrnes, Miroslav Bogdanovic, Avi Balakirsky, Stephen Balakirsky, Animesh Garg, International Conference on Robotics and Automation 2025 project page / arXiv A robot task planner that autonomously builds a library of causal world state predicates in the robot's environment by attempting tasks and learning from experience using a large language model teacher. |
Current Affiliations |
 |
Georgia Tech Research Institute - Aerospace, Transportation, and Advanced Systems Lab
Research Engineer II |
 |
Georgia Institute of Technology - People, AI, and Robots Lab
PhD Student (est. graduation 2029) |
|
Website template from Jon Barron. |